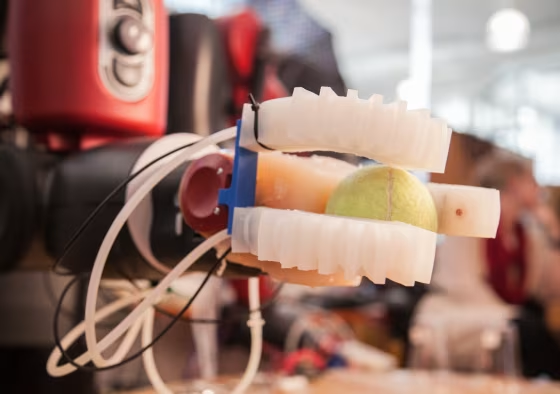
While robots are good at many things, picking up eggs and other fragile items isn't one of them — but a new soft robotic hand developed by scientists at MIT could change that. Formed from flexible silicone, the hand is more forgiving than plastic or metal, but that's not the only reason it can safely handle objects that would be dropped or crushed by less capable bots.
 FOR SUBSCRIBERSCBP leaders cut out of Trump ad buy decision
FOR SUBSCRIBERSA harrowing ordeal aboard an Israel-bound plane
Related: 'Big Hero 6': The Science Behind Baymax, Disney's Big, Soft Robot
Daniela Rus, director of the school's Computer Science and Artificial Intelligence Laboratory, equipped a Baxter robot, meant for imitating human movements, with a special three-pronged silicone gripper with accordion-like folds and a soft silicone palm to press objects against. Air pressure makes the prongs curl or relax, and each prong continuously sends back data on its curvature. Comparing this curvature with past gripping events allows allows the robot to determine what type of object it's holding without looking — much as humans do.
Related: Robot See, Robot Do: This AI Learns by Watching YouTube Videos
FOR SUBSCRIBERSCBP leaders cut out of Trump ad buy decision
FOR SUBSCRIBERSA harrowing ordeal aboard an Israel-bound plane
"If we want robots in human-centered environments, they need to be more adaptive and able to interact with objects whose shape and placement are not precisely known," said Rus in MIT's news release.
"Our dream is to develop a robot that, like a human, can approach an unknown object, big or small, determine its approximate shape and size, and figure out how to interface with it in one seamless motion."
